Proximity sensors are integral components in modern automation systems, enabling machines to detect the presence or absence of objects without physical contact. Among the various programming approaches, the "51 programming" method refers to techniques associated with the classic Intel 8051 microcontroller architecture, which remains widely used in industrial sensor applications due to its reliability and low cost. This guide provides a comprehensive overview of programming proximity sensors using 8051-based systems, focusing on practical implementation and optimization.
Understanding the hardware interface is the first step in proximity sensor 51 programming. Most inductive or capacitive proximity sensors connect to microcontrollers via digital input pins, though analog variants require ADC (Analog-to-Digital Converter) integration. The 8051 microcontroller typically interfaces with sensors through ports like P1 or P2, with external pull-up resistors ensuring stable signal readings. For instance, a common setup involves wiring the sensor's output to P1.0, configuring the pin as an input, and monitoring its state to detect object proximity. Developers must account for voltage levels—many industrial sensors operate at 12-24V, necessitating level-shifting circuits to match the 5V logic of the 8051.
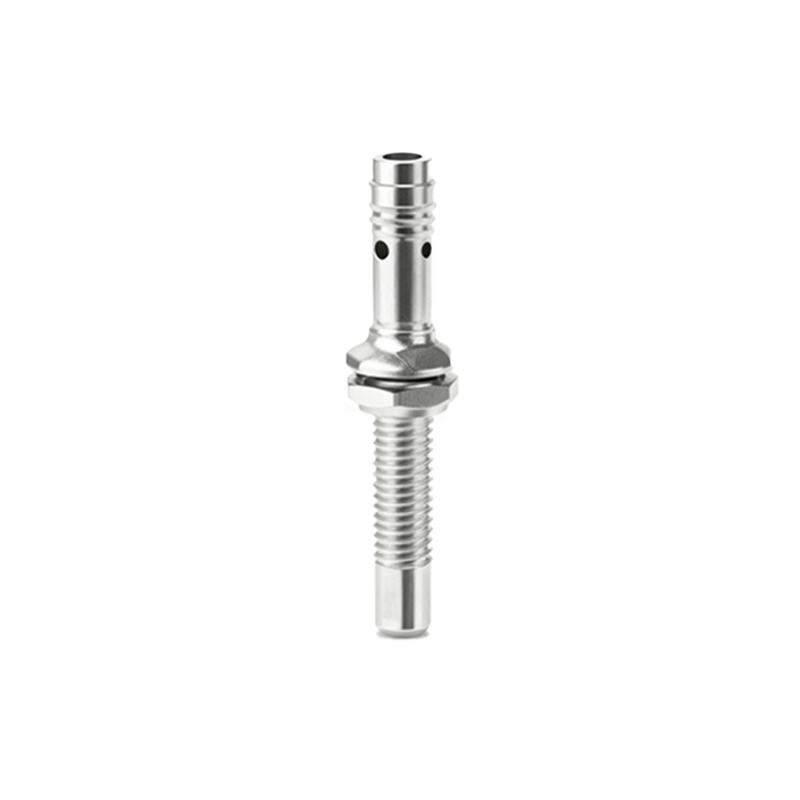
Programming begins with initializing the microcontroller's ports and timers. In assembly or C language, code must set up the necessary registers to define input/output modes. For example, to read a sensor on P1.0, the program clears the corresponding bit in the port configuration register. Debouncing is critical, as sensor signals may oscillate during state transitions. Implementing a software delay or using timer interrupts can filter false triggers. A simple code snippet in C for an 8051 might include a loop that checks P1.0, waits for a stable high or low signal, and then triggers an action like activating an LED or relay.
Advanced techniques involve integrating multiple sensors and communication protocols. In complex automation setups, several proximity sensors may connect to a single 8051, requiring multiplexed input handling or interrupt-driven designs. Using the 8051's built-in timers and serial communication modules (UART), programmers can enable data logging or remote monitoring. For instance, sensor states can be transmitted via RS-485 to a central control system, with the 8051 managing baud rate and data framing. Optimization tips include minimizing power consumption by putting the microcontroller into idle mode when sensors are inactive, leveraging the 8051's power-saving features.
Debugging and calibration are essential phases in proximity sensor programming. Common issues include signal interference from motors or electrical noise, which can be mitigated with shielding and proper grounding. Programmers should implement test routines to verify sensor range and response time, adjusting thresholds in code if needed. For analog sensors, calibration involves mapping ADC values to actual distance measurements, often using lookup tables or linear interpolation. Documentation and commenting code are best practices, ensuring maintainability in industrial environments where sensors may be replaced or reconfigured.
In summary, proximity sensor programming with 8051 microcontrollers combines foundational electronics with efficient coding practices. By mastering port manipulation, debouncing, and communication protocols, developers can create robust systems for applications ranging from conveyor belt monitoring to safety interlocks. The longevity of the 8051 architecture ensures that these skills remain relevant, offering a cost-effective solution for sensor-based automation. Future trends may involve migrating to more powerful microcontrollers, but the core principles learned in 51 programming provide a solid foundation for any embedded systems work.