Laser sensors have become integral components across numerous industries, offering precise, non-contact measurement and detection capabilities. Their classification is primarily based on the underlying operating principle, which dictates their application, performance, and suitability for specific tasks. Understanding these categories is essential for selecting the appropriate sensor for a given technological or industrial challenge.
The most fundamental categorization distinguishes between triangulation laser sensors and time-of-flight (ToF) laser sensors. Triangulation sensors operate on a simple geometric principle. The sensor emits a laser beam onto a target object. The reflected light is then captured by a receiver (typically a CMOS or CCD element) at a known angle relative to the emitter. By calculating the position of the reflected light spot on the receiver, the sensor's internal processor can determine the distance to the object with high accuracy. This method is exceptionally effective for short to medium-range measurements, often within a few millimeters to several meters, and provides very high resolution. Consequently, triangulation sensors are widely used in applications demanding micron-level precision, such as semiconductor wafer inspection, precision assembly, and profile measurement in manufacturing.
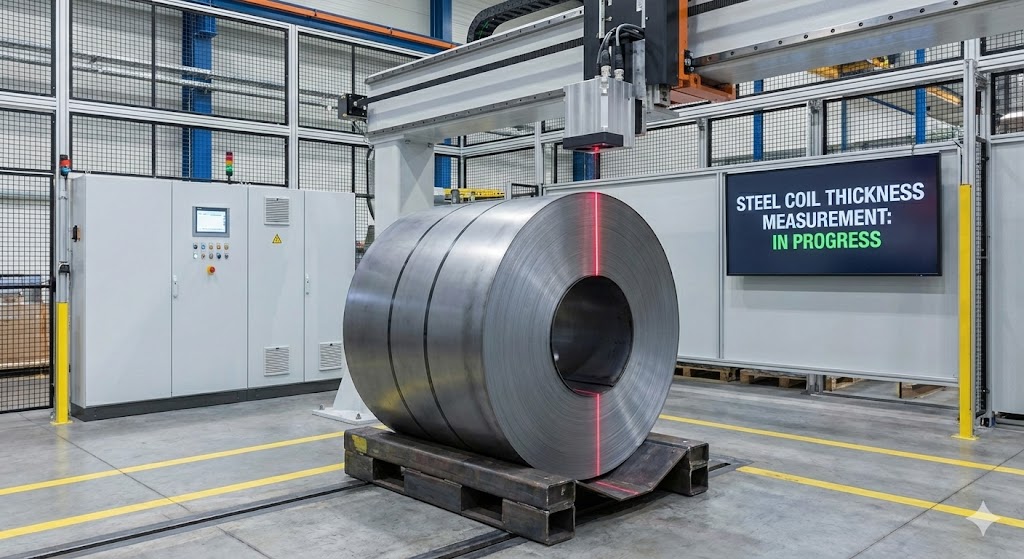
In contrast, Time-of-Flight (ToF) laser sensors measure distance by calculating the time it takes for a laser pulse to travel to the target and back. The sensor emits a short, powerful laser pulse and uses a high-speed receiver to detect its return. Since the speed of light is constant, the elapsed time is directly proportional to twice the distance to the object. ToF sensors are ideal for long-range measurements, from several meters up to hundreds or even thousands of meters. They are less affected by the target's surface color or reflectivity compared to some other methods, though extreme conditions can still pose challenges. Common applications include airborne LiDAR for topographic mapping, vehicle LiDAR for autonomous driving, and bulk level measurement in large silos or storage yards.
Another critical classification is based on the type of measurement output: 1D, 2D, and 3D laser sensors. A standard distance-measuring sensor provides a single-point measurement, known as 1D. When this laser point is scanned rapidly across a line, either by a moving mirror (galvanometer) or a rotating head, it creates a profile or line of data points, resulting in a 2D sensor. These are often called laser profile scanners or line scanners and are used for contour measurement, object dimensioning, and guidance. Extending this concept further, a 2D scan line can be moved across a second axis, or a ToF sensor can be equipped with a scanning mechanism to capture a full field of view, generating a dense point cloud. This creates a 3D laser scanner, the core technology behind 3D modeling, archaeological documentation, and advanced robotic vision systems.
We can also classify laser sensors by their functional purpose. Laser distance sensors are dedicated to precisely measuring the interval between the sensor and a target. Laser displacement sensors, a subset of distance sensors, are optimized for measuring the variation or movement of a target from a reference point, crucial for vibration analysis, thickness measurement, and runout detection. Laser photoelectric sensors are designed primarily for presence detection. They consist of a separate emitter and receiver (through-beam type), or a single unit that detects reflected light (retro-reflective or diffuse reflective types). These are workhorses in factory automation for object counting, positioning, and break-beam safety curtains.
Furthermore, the type of laser light source used can be a distinguishing factor. While most industrial sensors use visible red lasers or infrared lasers, some specialized applications employ blue lasers. Blue laser light has a shorter wavelength, which scatters less on certain surfaces, particularly shiny or transparent materials like glass or polished metal. This results in a sharper, more stable light spot, improving measurement stability and accuracy on challenging surfaces that would cause errors for a standard red laser.
The choice of a laser sensor is a multifaceted decision. Factors such as required measurement range, accuracy, resolution, response speed, target surface properties, and environmental conditions (ambient light, dust, temperature) all play a decisive role. A triangulation sensor excels in high-precision, short-range factory floor tasks, while a ToF sensor is unmatched for long-range surveying. A 2D profile scanner is perfect for inspecting cross-sections on a conveyor belt, and a 3D scanner is indispensable for reverse engineering. By thoroughly understanding the classifications based on operating principle, dimensionality, function, and light source, engineers and system integrators can effectively navigate the vast landscape of laser sensing technology and deploy the optimal solution to enhance efficiency, quality, and automation in their respective fields.