Introduction to Proximity Sensor Classification
In the realm of industrial automation and electrical engineering, proximity sensors are indispensable components for non-contact detection. Their primary function is to detect the presence or absence of an object within a specified range without any physical contact. The classification of these sensors is fundamental for selecting the right component for a specific application, ensuring reliability, efficiency, and cost-effectiveness. This classification is primarily based on the underlying sensing technology, which dictates the sensor's operating principles, suitable target materials, sensing ranges, and environmental robustness. Understanding these categories allows engineers to make informed decisions in system design and integration.
Inductive Proximity Sensors
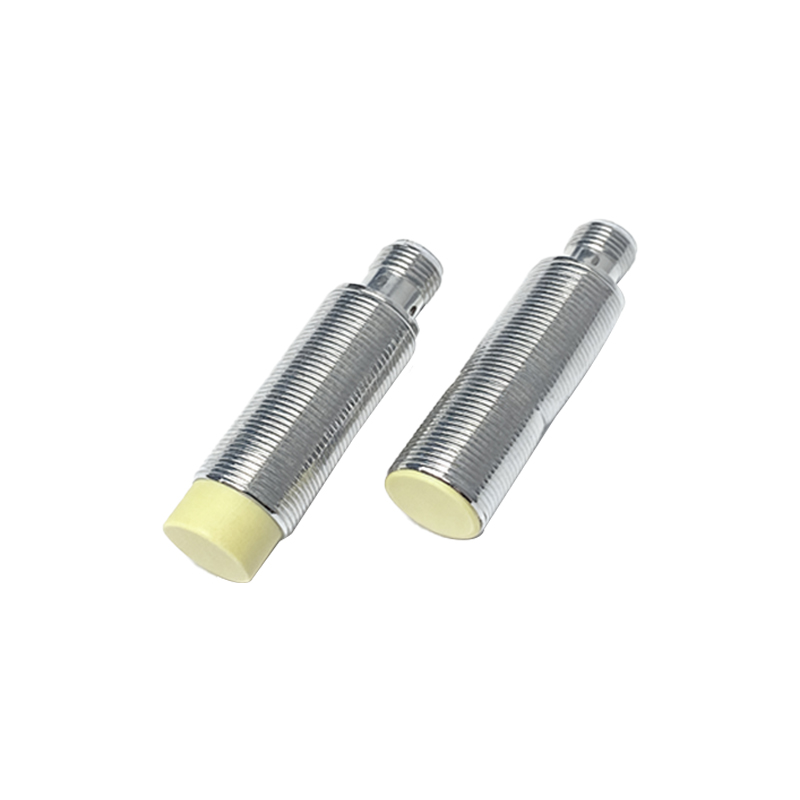
Inductive proximity sensors are among the most common types used in industrial settings. They operate on the principle of electromagnetic induction. The sensor generates an oscillating electromagnetic field from its coil. When a metallic object, typically ferrous metals like iron or steel, enters this field, it induces eddy currents within the target. These currents cause a change in the oscillation amplitude, which is detected by the sensor's circuitry, triggering an output signal. A key characteristic is that they only detect metallic objects. They are highly robust, resistant to environmental factors like dust, oil, and moisture, and offer high switching frequencies. Common applications include position sensing in machine tools, part detection on conveyor belts, and limit switching.
Capacitive Proximity Sensors
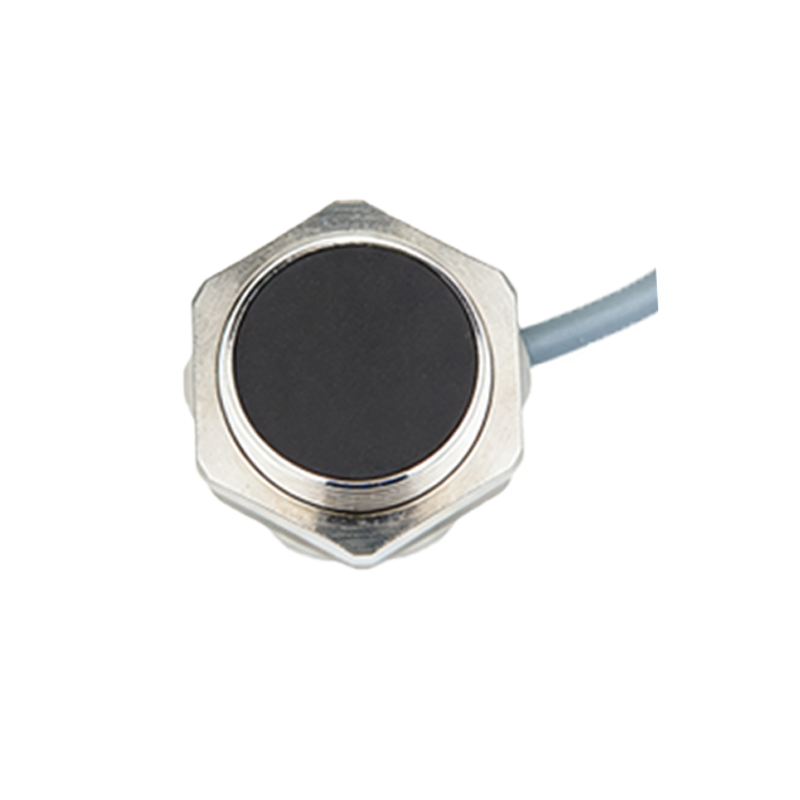
Capacitive proximity sensors function by detecting changes in capacitance. The sensor's active face and the target act as two plates of a capacitor. The sensor generates an electrostatic field. When any object, be it metallic or non-metallic (such as plastic, glass, wood, or liquids), enters this field, it alters the dielectric constant and thus the capacitance of the system. This change is measured, and when it exceeds a threshold, the sensor switches its output. These sensors can detect a wider variety of materials compared to inductive types. They are often used for level detection in tanks (for liquids or granules), material handling, and detecting non-metallic objects through thin barriers.
Ultrasonic Proximity Sensors
Ultrasonic sensors utilize sound waves at frequencies above the human hearing range (typically >20 kHz). They operate on the time-of-flight principle. The sensor emits ultrasonic pulses and then listens for the echo reflected from a target object. By calculating the time difference between the emission and reception of the pulse, the sensor can determine the distance to the object. They are excellent for detecting objects regardless of material, color, or transparency, and are effective over longer ranges. Applications are diverse, including distance measurement, object detection in harsh environments (with dust or fog), and liquid level sensing. However, they can be affected by temperature variations and air turbulence.
Photoelectric Proximity Sensors
Photoelectric sensors, or photoeyes, use light beams to detect objects. They consist of a light emitter (usually an LED) and a receiver. They are further classified into three main sub-types based on their operating mode. The through-beam type has separate emitter and receiver units; an object is detected when it interrupts the light beam. The retro-reflective type uses a single unit and a reflector; detection occurs when the beam is blocked from returning. The diffuse-reflective type detects objects by measuring the light reflected directly from the target itself. Photoelectric sensors offer very long sensing ranges and can detect virtually any material. They are ideal for packaging, material handling, and assembly line automation, though they can be susceptible to ambient light and dirty lenses.
Magnetic Proximity Sensors
Magnetic proximity sensors, often called reed switches or Hall-effect sensors, detect the presence of a magnetic field. Reed switches consist of two ferromagnetic reeds sealed in a glass tube; when a magnet approaches, the reeds attract and close the electrical contact. Hall-effect sensors produce a voltage output proportional to the strength of an applied magnetic field. These sensors are used to detect permanent magnets, typically embedded in moving parts like cylinders or doors. They are simple, reliable, and can operate in explosive environments as they are hermetically sealed and generate no spark. Common uses include position sensing in pneumatic cylinders, door/window security systems, and speed detection.
Selection Criteria and Conclusion
Choosing the correct proximity sensor requires careful analysis of several factors beyond just the technology type. Key selection criteria include the nature of the target material (metal, plastic, liquid), the required sensing distance, the operating environment (temperature, presence of contaminants, humidity), the required response speed (switching frequency), and the output type (PNP/NPN, analog, IO-Link). For instance, an inductive sensor is perfect for detecting a metal gear