In the realm of industrial automation and electrical control systems, proximity sensors are indispensable components. These non-contact devices detect the presence or absence of an object within their sensing range, triggering an output signal without physical contact. This capability makes them ideal for harsh environments, high-speed counting, positioning, and object detection applications where reliability, longevity, and precision are paramount. Understanding the various types of proximity sensors is crucial for selecting the right technology for a specific application. This guide delves into the primary categories, their operating principles, advantages, and typical use cases.
The most common classification of proximity sensors is based on their underlying detection technology. The four fundamental types are Inductive, Capacitive, Ultrasonic, and Photoelectric sensors.
Inductive Proximity Sensors
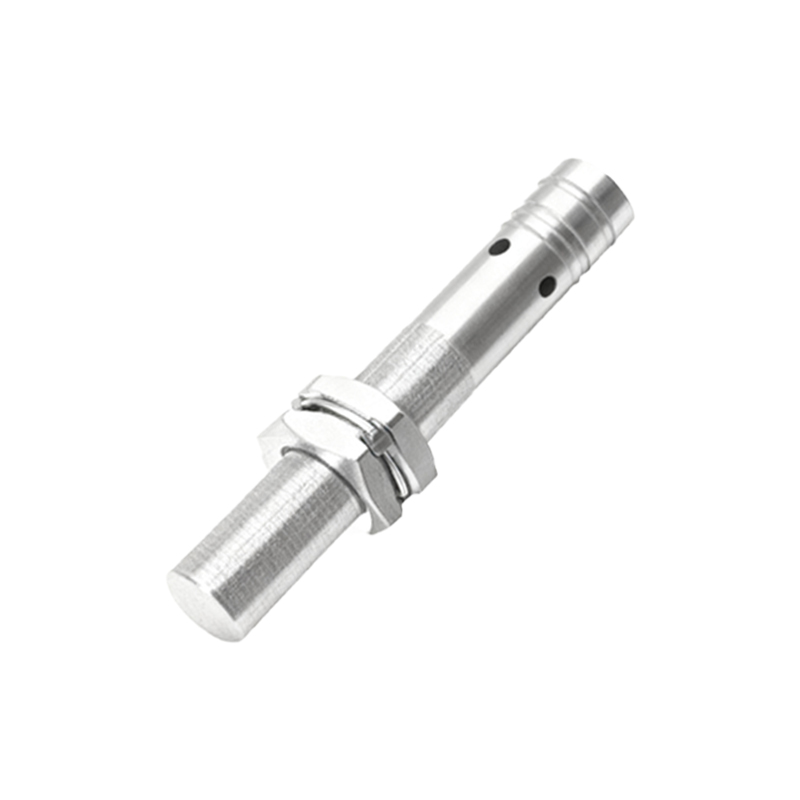
Inductive proximity sensors are designed to detect metallic objects, primarily ferrous metals like iron and steel, though some models can also sense non-ferrous metals like aluminum, copper, and brass with reduced sensing range. Their operation relies on electromagnetic induction. The sensor's oscillator circuit generates a high-frequency electromagnetic field from its sensing face. When a metallic target enters this field, eddy currents are induced on the metal's surface. This causes a change in the oscillation amplitude, which is detected by the sensor's threshold circuit, subsequently switching the output state (e.g., from OFF to ON).
Key advantages include robustness, high switching frequency, and immunity to environmental factors like dust, oil, and moisture. They are widely used in machine automation for tasks such as detecting piston position in cylinders, monitoring gear teeth, part presence verification on conveyor lines, and as end-position sensors.
Capacitive Proximity Sensors
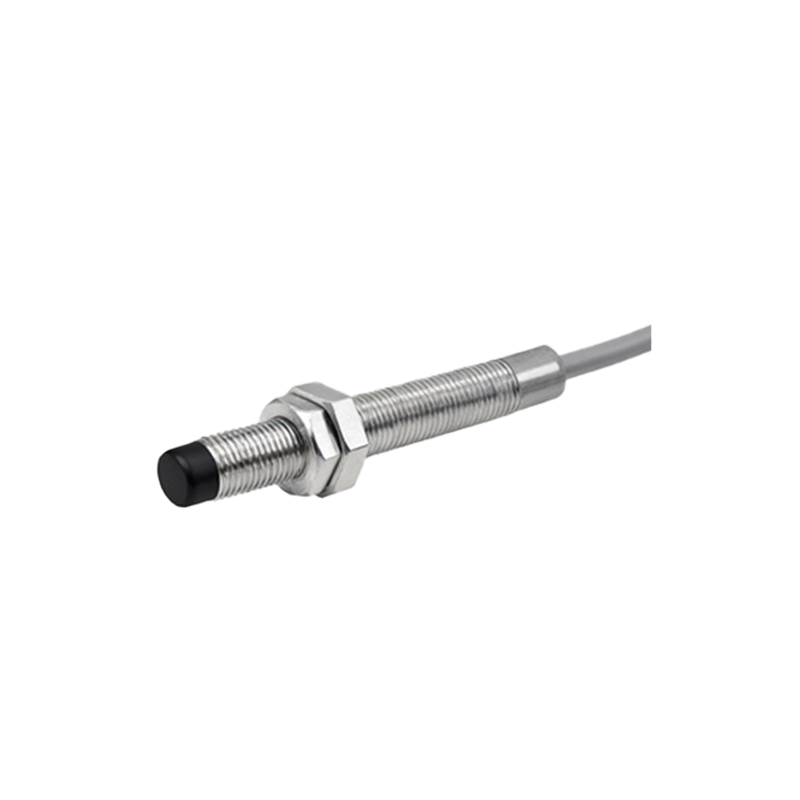
Capacitive sensors can detect both metallic and non-metallic materials, including liquids, powders, plastics, glass, and wood. They operate by measuring changes in capacitance. The sensor acts as one plate of a capacitor, with the target object acting as the other plate. An oscillator circuit creates an electrostatic field from the sensing face. When any material with a dielectric constant different from air enters this field, it alters the capacitance, changing the oscillator's amplitude. This change triggers the output.
These sensors are versatile and can detect materials through non-metallic barriers, making them suitable for level detection of liquids or granular solids in tanks, presence detection of packaged goods, and touch interfaces. However, they can be more susceptible to environmental factors like humidity and temperature variations compared to inductive types.
Ultrasonic Proximity Sensors
Ultrasonic sensors use sound waves beyond the human hearing range (typically above 20 kHz). They operate on the principle of echolocation. The sensor emits ultrasonic pulses from a transducer. These pulses travel through the air, hit a target object, and reflect back to the sensor. The control electronics measure the time interval between emission and reception of the echo to calculate the distance to the object. They can detect virtually any solid or liquid object, regardless of color, transparency, or material composition.
Their primary strengths are long sensing ranges and reliable detection of transparent or poorly reflective objects that challenge photoelectric sensors. Common applications include pallet detection, loop control in winding machines, distance measurement, and level monitoring in bulk material handling. Performance can be affected by temperature, air turbulence, and the object's sound-absorbing properties.
Photoelectric Sensors
Photoelectric sensors utilize light beams to detect objects. They consist of a light emitter (usually an LED emitting visible red, infrared, or laser light) and a receiver. They are further subdivided into three main operating modes:
1. Through-beam (Opposed): The emitter and receiver are separate units placed opposite each other. Detection occurs when the target object interrupts the light beam. This mode offers the longest range and highest reliability.
2. Retro-reflective: The emitter and receiver are housed in the same unit. A reflector is placed opposite the sensor. The sensor detects an object when it breaks the light beam between the sensor and the reflector. Range is shorter than through-beam.
3. Diffuse (Proximity): The emitter and receiver are in the same housing. The sensor detects light reflected directly off the target object. Sensing range is shortest and depends on the object's color, texture, and reflectivity.
Photoelectric sensors excel at long-range detection and can sense small objects. They are used for bottle counting on fill lines, label detection, web break detection, and door safety curtains. They may struggle with transparent objects or in environments with heavy dust, fog, or ambient light interference.
Magnetic Proximity Sensors (Reed Switches)
While less common in high-speed industrial sensing, magnetic proximity sensors, often using sealed reed switches or Hall-effect chips, are vital for specific applications. They detect the presence of a permanent magnet. When the magnet approaches, the contacts inside the reed switch close (