As an experienced electrical engineer specializing in industrial automation, I often encounter questions about laser sensor mapping—specifically, how to accurately read and interpret the data these sophisticated devices generate. Laser sensors, particularly those used for mapping applications like LiDAR (Light Detection and Ranging), produce rich datasets that form the backbone of many modern systems, from autonomous vehicles to precision manufacturing and robotic guidance. Understanding this data is not just about reading numbers; it's about visualizing spatial relationships and making informed decisions based on point clouds, intensity values, and environmental models.
First, let's clarify what we mean by "mapping" in this context. A laser sensor emits pulsed or continuous-wave laser beams that scan across a target area. By measuring the time it takes for each beam to reflect back to the sensor (time-of-flight principle), the device calculates distances with high precision. These distance measurements, combined with the sensor's known orientation and position, generate a collection of data points in three-dimensional space—commonly known as a point cloud. Each point in this cloud has coordinates (X, Y, Z) and often additional attributes like reflectance intensity, which indicates how much laser light was returned from the surface.
To effectively interpret laser sensor mapping, start with the point cloud visualization. Specialized software tools (e.g., CloudCompare, MATLAB, or proprietary suites from sensor manufacturers) are used to render these points. When you first open a point cloud dataset, look for the overall structure: Are points densely clustered in certain areas? Are there gaps or noise? A well-calibrated sensor in a controlled environment typically produces a clean, coherent cloud that closely resembles the physical scene. For instance, in a factory setting mapping a conveyor assembly, you should clearly see distinct planes representing floors, walls, and machinery surfaces. Irregularities like stray points or "ghost" echoes might indicate sensor issues (e.g., multipath interference from reflective surfaces) or environmental factors like dust or fog.

Next, analyze the intensity layer. Intensity values, often represented on a grayscale or color gradient, provide material information. Surfaces that are highly reflective (like metal or white paint) return stronger signals, resulting in higher intensity values, while absorptive or dark surfaces yield lower values. By examining intensity, you can differentiate between objects made of different materials even if they have similar shapes. For example, in topographic mapping, high-intensity returns might indicate bare rock or pavement, while low-intensity areas could correspond to vegetation or soil. This layer is crucial for applications like infrastructure inspection, where corrosion or coating degradation might manifest as localized intensity drops.
Another key aspect is understanding coordinate systems and registration. Laser sensor data is typically collected in the sensor's local coordinate system. For practical use, this data often needs to be transformed into a global or project-specific coordinate system (e.g., WGS84 for geographic mapping or a factory-floor CAD coordinate system). Proper registration—aligning multiple scans or integrating sensor data with other sources like GPS or IMU (Inertial Measurement Unit) data—is essential for accuracy. Misalignment can lead to errors in distance measurements or object recognition. Always check registration quality by looking for overlapping areas between scans; they should align seamlessly without visible offsets or distortions.
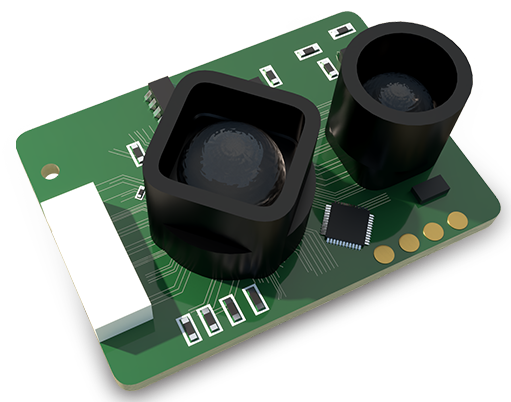
Feature extraction is the advanced stage of interpretation. Here, you move from raw points to meaningful geometric features: planes, edges, cylinders, and complex shapes. Algorithms (such as RANSAC or region-growing segmentation) can automatically detect these features. For instance, in autonomous vehicle mapping, extracting road planes, curb edges, and pedestrian shapes is critical. When reviewing extracted features, validate them against known ground truth. Ask: Do the detected planes correspond to actual flat surfaces? Are edges sharp and continuous? In industrial quality control, a laser sensor mapping a machined part might extract dimensions; deviations from CAD models could indicate manufacturing defects.
Environmental context and noise filtering are equally important. Real-world settings introduce challenges: dynamic objects (like moving people or vehicles), atmospheric conditions, and sensor limitations (e.g., limited range or angular resolution). Most software includes filtering tools to remove outliers—isolated points that don't belong to the main scene. However, over-filtering can erase valid data. A balanced approach involves setting thresholds based on expected noise levels and reviewing filtered results layer by layer. Always consider the operational context; for example, in a busy warehouse, temporary obstructions might be filtered out, but permanent structural features should be retained.
Finally, leverage quantitative metrics for validation. Key performance indicators (KPIs) like point density (points per square meter), accuracy (compared to reference measurements), and repeatability (consistency across multiple scans) provide objective measures of mapping quality. Document these metrics alongside visual inspections. For ongoing projects, establish a baseline dataset to compare against future scans, enabling trend analysis for applications like structural monitoring or wear-and-tear assessment in machinery.
In summary, interpreting laser sensor mapping is a multifaceted skill combining technical knowledge of sensor operation, proficiency with analysis software, and practical experience in the target environment. By systematically examining point clouds, intensity data, coordinate alignment, extracted features, and noise factors, engineers can transform raw laser data into actionable insights, driving efficiency and innovation across industries. Remember, the map is not the territory—but a well-interpreted map brings you remarkably close.