In the realm of precision measurement and industrial automation, laser displacement sensors stand as a cornerstone technology. Their ability to provide non-contact, high-speed, and highly accurate distance measurements has revolutionized quality control, robotics, and process monitoring. While specifications like resolution, repeatability, and sampling rate are often the initial focus, one parameter is fundamental to overall system accuracy: linearity. This article delves into the concept of linearity in laser displacement sensors, exploring its definition, influencing factors, calibration methods, and its critical importance in real-world applications.
At its core, linearity refers to the degree to which the sensor's output signal (typically voltage or digital value) deviates from a perfectly straight line when plotted against the actual physical displacement of the target object. In an ideal world, a displacement of X millimeters would always produce an output of Y volts, following a perfectly linear relationship across the entire measuring range. In reality, all sensors exhibit some degree of non-linearity due to optical, electronic, and algorithmic imperfections. Linearity error is usually expressed as a percentage of the full-scale range (FS). For instance, a sensor with a ±30mm range and a linearity of ±0.1% FS has a maximum potential deviation of ±0.03mm from the true linear output across that entire 60mm span. It is crucial to distinguish linearity from accuracy; accuracy encompasses linearity error along with other errors like offset and hysteresis.
Several key factors within the sensor's design and operating environment influence its linearity performance. The optical system is paramount. The type of laser (e.g., red laser, blue laser for reduced speckle), the lens quality, and the geometry of the light reception (triangulation method being most common) directly affect how the light spot is imaged onto the position-sensitive detector (PSD or CMOS/CCD). Any distortion in this imaging path introduces non-linearity. The algorithm used to calculate the centroid of the received light spot is equally critical. Sophisticated digital signal processors (DSPs) run complex correction algorithms to compensate for inherent optical non-linearity. Environmental factors also play a role. Significant temperature fluctuations can cause thermal expansion in mechanical components and alter electronic characteristics, potentially affecting linearity if not properly compensated. Furthermore, the target surface characteristics—its color, material, roughness, and angle—can influence the reflected light intensity and pattern, potentially introducing measurement errors that manifest as non-linearity under varying conditions.
To ensure high linearity, manufacturers employ rigorous calibration procedures. This typically involves moving a highly precise reference target (e.g., a glass scale or a stage controlled by a laser interferometer) through the sensor's entire measuring range in minute increments. The sensor's raw output is recorded at each point and compared against the "ground truth" displacement. A correction table or a high-order polynomial function is then generated and stored in the sensor's memory. In operation, the sensor's internal processor uses this calibration data to correct its raw output in real-time, delivering a linearized signal. For the most demanding applications, some sensors allow for user-specific linearity compensation for a particular target surface, further minimizing application-specific errors.
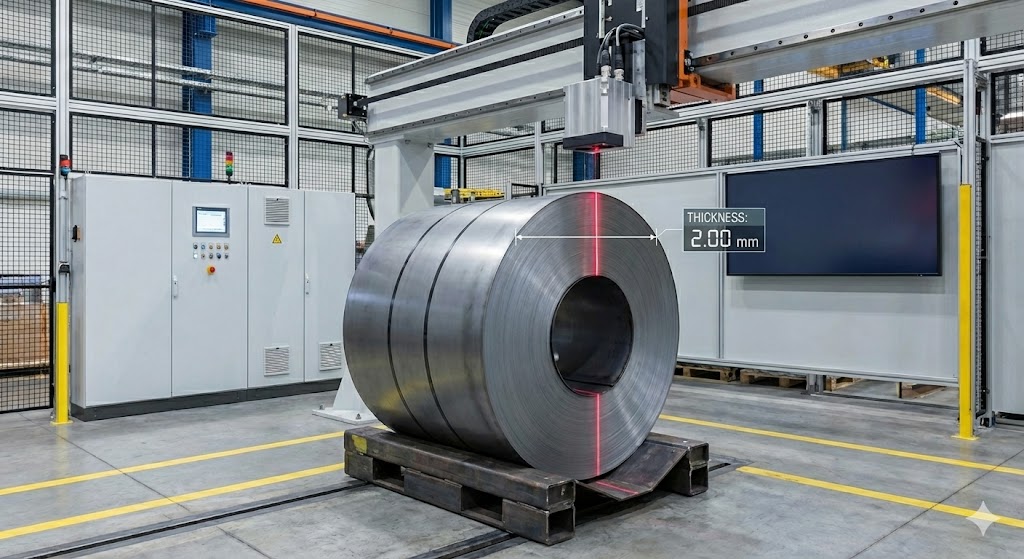
The implications of linearity error are profound in industrial settings. Consider a system inspecting the thickness of rolled metal sheets. A non-linear sensor might correctly measure the nominal thickness but provide increasingly erroneous readings towards the edges of its range, leading to false acceptance or rejection of product. In robotic guidance for precise assembly, non-linearity could cause a robot arm to misplace a component by a variable amount depending on its distance from the sensor, resulting in assembly failures. In vibration analysis of rotating machinery, non-linearity distorts the waveform of the displacement measurement, leading to incorrect analysis of amplitude and frequency components. Therefore, selecting a sensor with an appropriate linearity specification for the task is not a mere box-ticking exercise; it is integral to ensuring measurement integrity.
When integrating a laser displacement sensor, engineers must consider linearity in context. First, always consult the datasheet under the specified standard conditions (target surface, temperature). The stated linearity is often achieved under ideal laboratory conditions (e.g., a white, matte, perpendicular target). Second, understand that linearity error is typically worst at the extremes of the measuring range. It is often good practice to design the system so that the nominal working point is near the center of the sensor's range. Third, for dynamic measurements, ensure the sensor's linearity is specified across the entire bandwidth, not just at DC. Finally, regular verification against a traceable standard is recommended in critical applications to ensure the calibration remains valid over time.
In conclusion, linearity is a defining characteristic of a laser displacement sensor's performance, underpinning its ultimate measurement accuracy. By understanding its principles, causes of error, and compensation techniques, engineers can make informed selection decisions, implement sensors correctly, and troubleshoot measurement systems effectively. In the pursuit of micron-level precision, a deep appreciation of linearity transforms it from a datasheet parameter into a fundamental pillar of reliable metrology.