Proximity sensors are indispensable components in modern industrial automation, providing non-contact detection of objects within a specific range without physical touch. Their operation hinges on various physical principles, each suited to different materials, environments, and applications. Understanding these core principles is crucial for selecting the right sensor for a specific task.
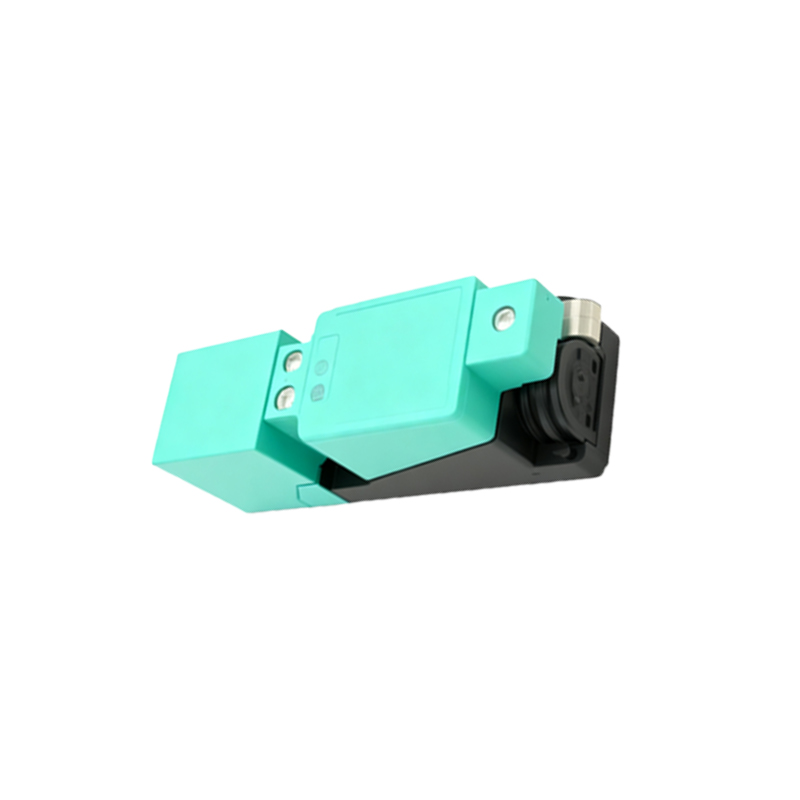
The most prevalent type is the inductive proximity sensor. This sensor generates an electromagnetic field via a coil in its oscillator circuit. When a metallic object enters this field, eddy currents are induced on the object's surface. These currents draw energy from the sensor's oscillator, causing a reduction in oscillation amplitude. This change is detected by the sensor's threshold circuit, which subsequently triggers a solid-state output switch. Inductive sensors are highly reliable for detecting ferrous and non-ferrous metals but are ineffective for non-metallic materials.
Capacitive proximity sensors operate on a different principle. They function like an open capacitor, with the sensor's face acting as one plate and the target object as the other. The sensor generates an electrostatic field. When any object, metallic or non-metallic (like plastic, wood, or liquid), enters this field, it alters the dielectric constant and thus the capacitance of the system. This capacitance change is measured, and when it exceeds a preset threshold, the sensor switches its output state. This makes capacitive sensors versatile for detecting a wide array of materials, including through certain non-metallic container walls.
Magnetic proximity sensors, often referred to as reed switches or Hall-effect sensors, detect the presence of a magnetic field. Reed switches consist of two ferromagnetic reeds sealed in a glass tube. When a permanent magnet approaches, the reeds magnetize and attract each other, closing the contact. Hall-effect sensors, which are solid-state, produce a voltage difference (the Hall voltage) when exposed to a magnetic field. This voltage is processed to provide a digital output. These sensors are ideal for detecting magnets and are commonly used in cylinder position sensing and speed detection.
Ultrasonic proximity sensors utilize sound waves beyond human hearing. They emit high-frequency ultrasonic pulses and measure the time taken for the echo to return after bouncing off a target object. The time-of-flight calculation determines the object's distance. Unlike other types, ultrasonic sensors can provide precise distance measurement, not just presence detection, and are effective for detecting solids, liquids, and granular materials, even in dusty or steamy environments where optical methods might fail.
Photoelectric sensors, while sometimes categorized separately, function on a proximity principle in their diffuse reflective mode. They consist of an emitter (usually an LED) and a receiver. The emitter projects a light beam. In the diffuse mode, the sensor detects light reflected directly off the target object back to the receiver. The detection occurs when the received light intensity surpasses a set level. They excel at detecting non-metallic objects and offer longer sensing ranges than inductive or capacitive sensors.
The selection of the appropriate proximity sensor principle depends on several factors: target material (metal, plastic, liquid), required sensing distance, environmental conditions (presence of dust, moisture, or electrical noise), response speed, and output requirements. Inductive sensors dominate metal detection in machinery. Capacitive sensors handle material level detection and non-metallic object sensing. Magnetic sensors are key for safety and position feedback. Ultrasonic sensors provide robust solutions for challenging environments and distance control. Each principle offers a unique solution, forming the sensory foundation for efficient, reliable, and automated industrial systems. Proper application ensures enhanced machine safety, precise process control, and optimized productivity.